Yixiao Liu

Yixiao Liu

M.S.E. Student, University of Pennsylvania · Robotics & AI

Researching world models, robot learning, and embodied AI.

Introduction

I am currently an M.S.E. student in Mechanical Engineering and Applied Mechanics at the University of Pennsylvania. My research interests lie in world models, robot learning, and robotic perception. I am broadly interested in learning predictive representations of the physical world and leveraging them for embodied intelligence and robot control.

Education

University of PennsylvaniaM.S.E. in Mechanical Engineering and Applied MechanicsAccelerated Master’s Program with Shanghai Jiao Tong University (3+1+1)
Aug 2025 – Expected Jun 2027
Shanghai Jiao Tong UniversityB.S. in Mechanical Engineering
Aug 2022 – Jun 2026

Selected publications

All publications →
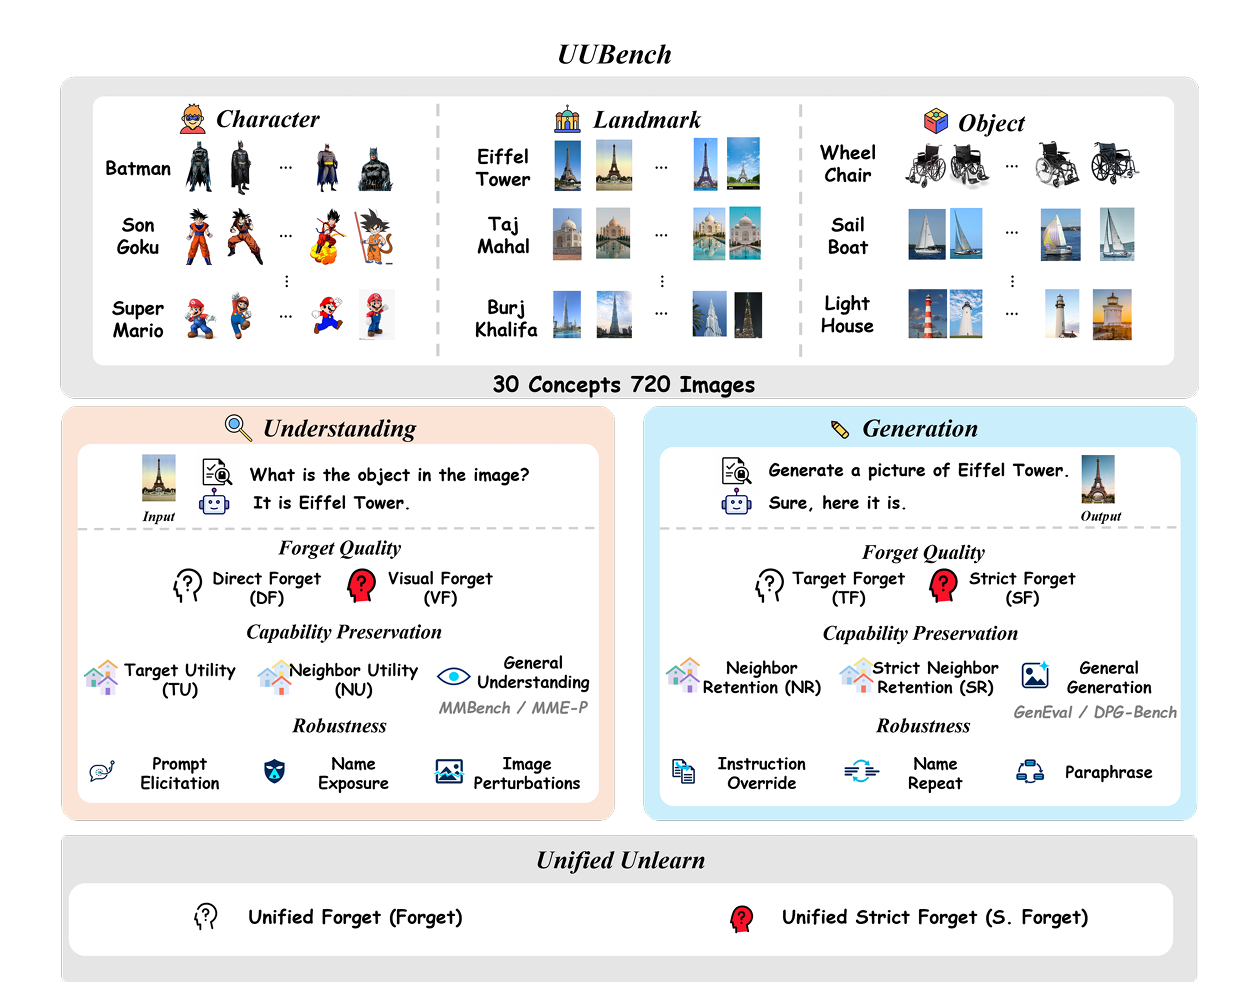
UUBench overview of concept unlearning across visual understanding and image generation.Open full-size figure

Is Forgetting Unified? Exploring Concept Unlearning in Unified Multimodal Models

Zhongkai Xue, Junkai Chen, Mingcong Lei, Rumo Zhang, Yixiao Liu, Zhimin Sun, Shu Wu, Qiang Liu, Lihua Zhang, Liang Wang

Unified multimodal models can generate images and understand visual content, but forgetting a concept in one pathway does not necessarily remove it from the other. We introduce UUBench to evaluate cross-pathway concept unlearning and propose UniForget to jointly suppress target concepts while preserving other model capabilities.
Featured projects

All projects →
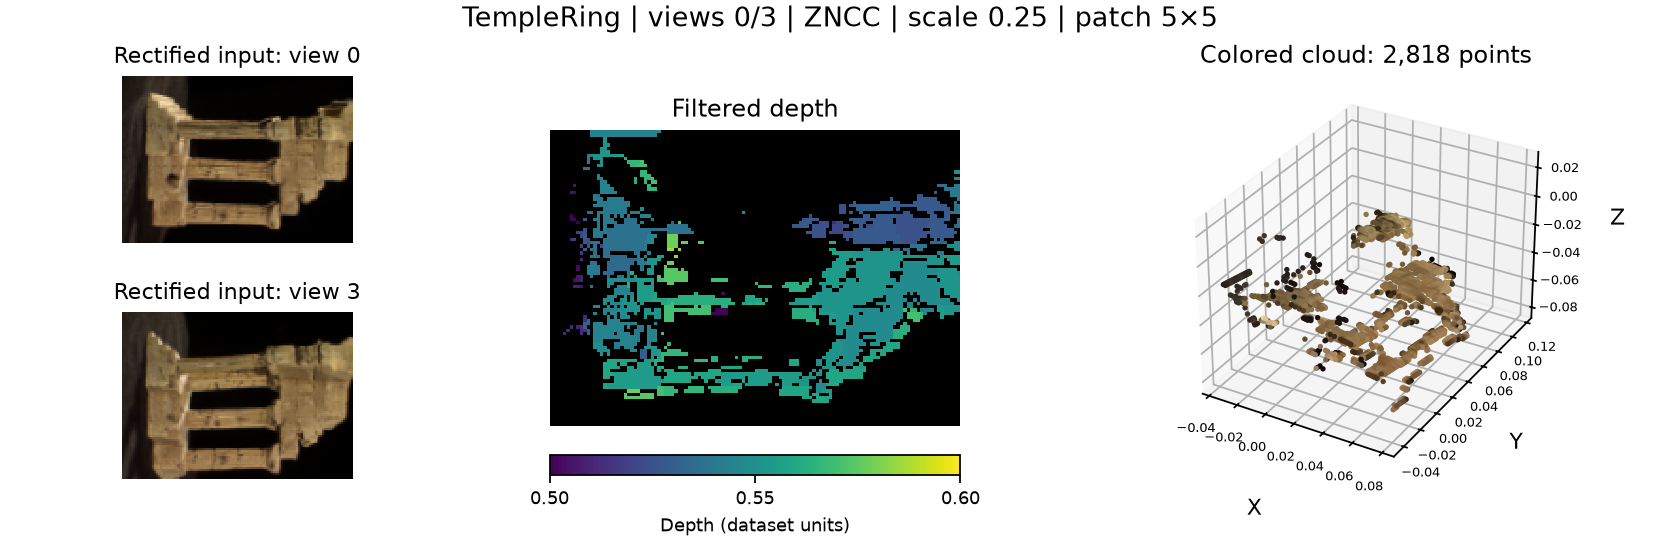
Rectified stereo input, reconstructed depth and colored point cloud

3D Reconstruction and Neural Rendering

Spring 2026

Calibrated stereo reconstruction and NeRF evaluation: 24.19 dB PSNR / 0.831 SSIM over six 100×100 test views in one scene.

Stereo vision · NeRF · PyTorch

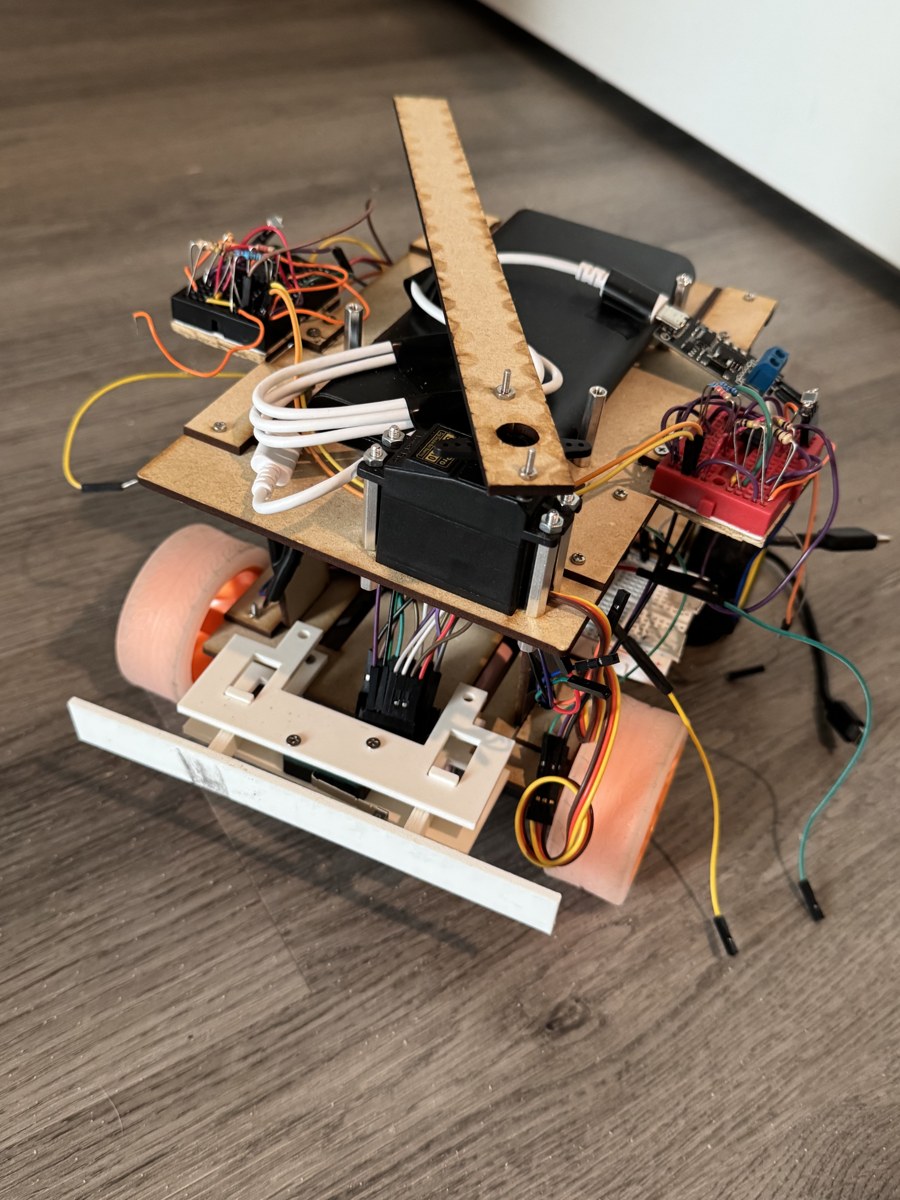
Physical ROBA robot with MDF frame, four-wheel drive, servo mechanism and sensors

ROBA Mobile Robot and Embedded Control

Fall 2025

ESP32 master/slave sensing, Python gamepad control, wall following, Vive target navigation and timed competition-task sequences.

ESP32 · Python · Embedded control · Hardware

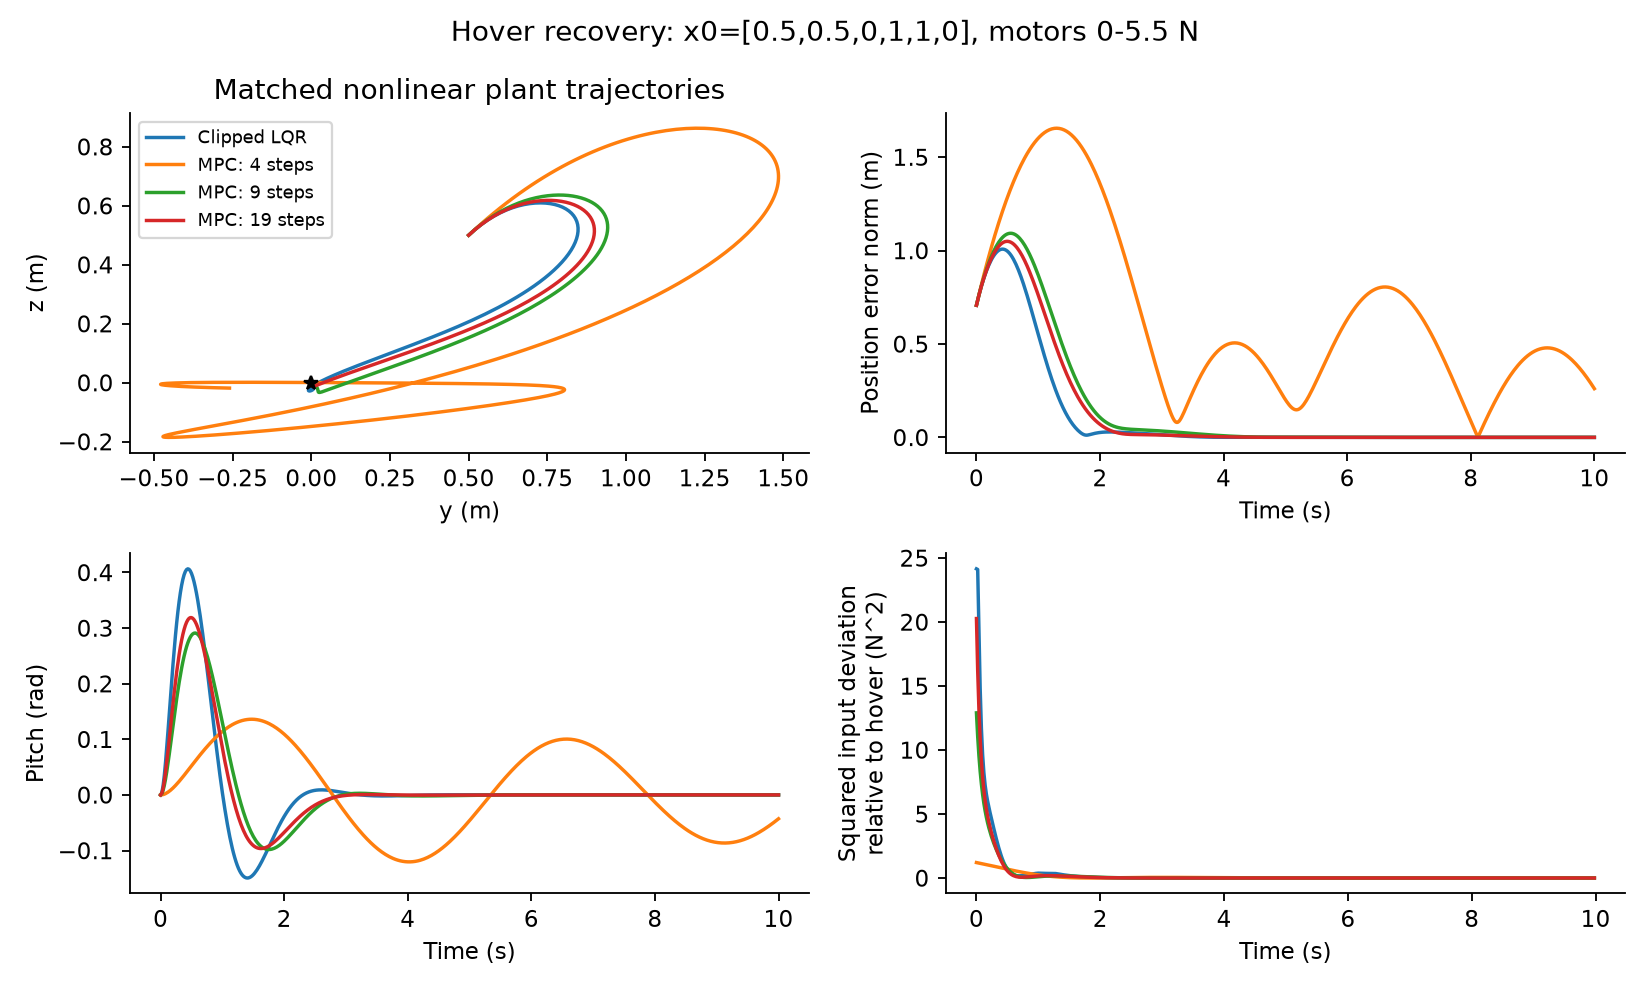
State and input plots comparing planar quadrotor LQR and MPC hover recovery

Robotic Motion Planning and Optimal Control

Fall 2025

Input-constrained MPC and clipped LQR on a nonlinear planar quadrotor, alongside minimum-snap waypoint planning.

Python · NumPy · SciPy · OSQP

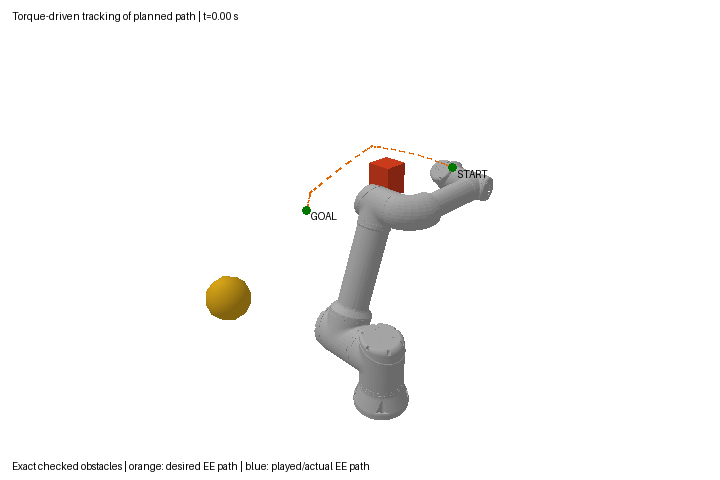
UR16e simulated arm and end-effector path around an obstacle

UR16e Motion Planning and Control

Jun–Aug 2025

Collision-checked RRT paths, smooth joint timing and torque-driven tracking, checked against independent dynamics calculations.

Python · PyBullet · RRT · Dynamics

Contact